基本资料
徐灵敏 特聘教授,硕士生导师,浙江理工大学博士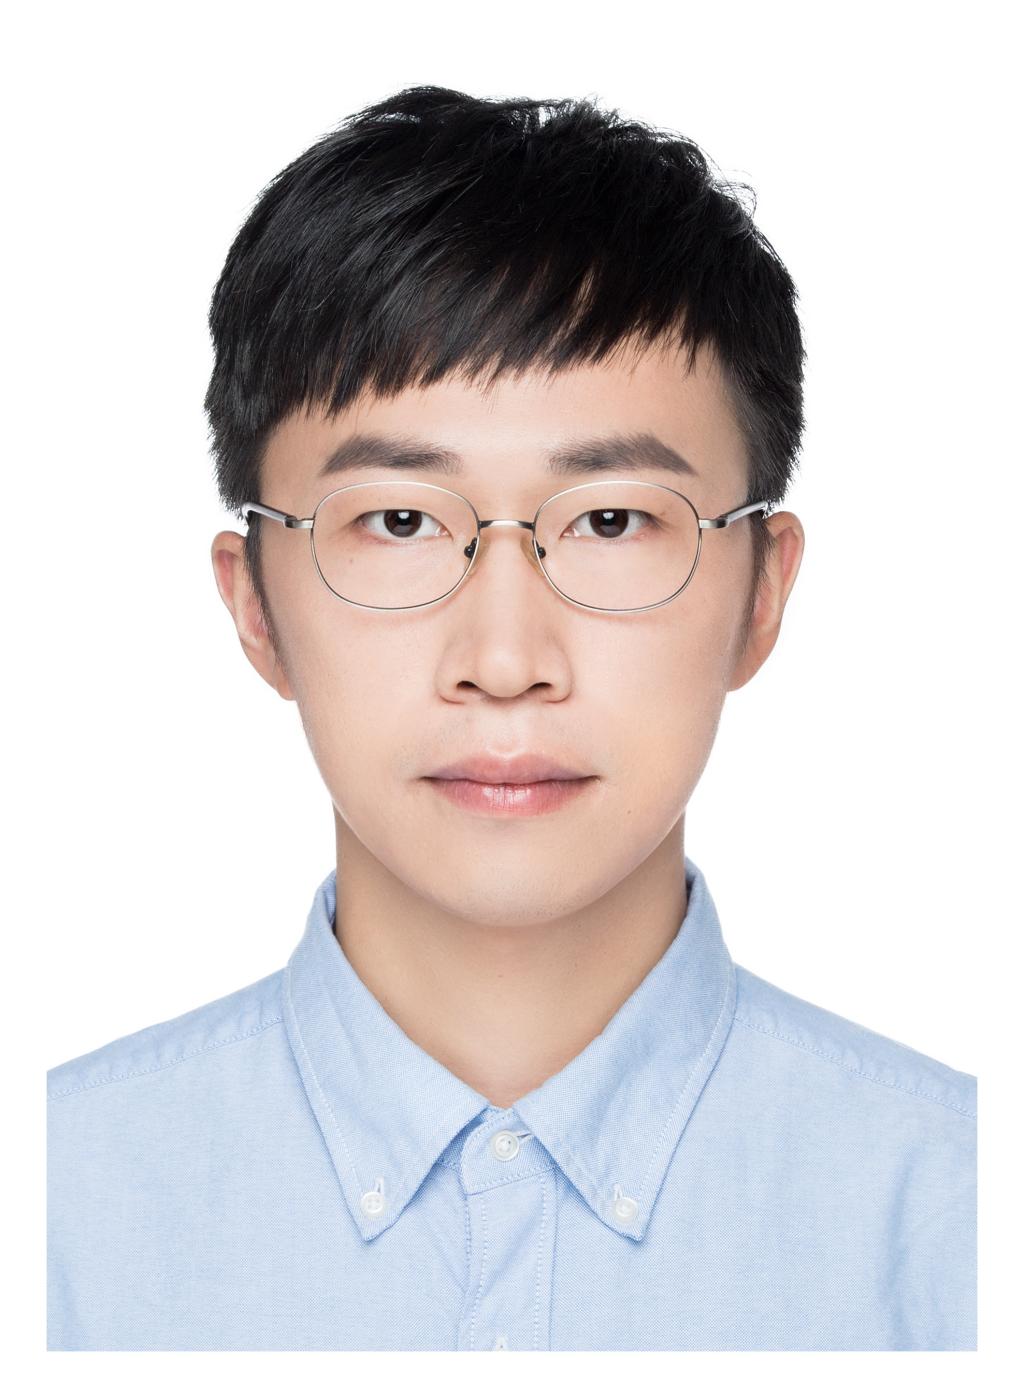 ,上海交通大学博士后,入选第九届中国科协“青年人才托举工程”、浙江理工大学“青年拔尖人才培养计划”。主要研究领域包括并/混联机器人机构构型综合、力学建模及性能设计、装备研发及应用、人形机器人结构设计等。担任《机械工程学报》、《SmartBot》期刊青年编委、中国机械工程学会生产工程分会机床专业委员会委员、第六届浙江省青年科学技术协会智能制造专委会委员。主持中国科协“青年人才托举工程”、国家自然科学基金面上/青年、浙江省自然科学基金重点项目等国家/省部级项目8项,参与国家自然科学基金杰青/重点/面上项目、国家重点研发计划项目等5项。研究成果在Journal of Mechanisms and Robotics-Transactions of the ASME、Mechanism and Machine Theory、机械工程学报等权威期刊/会议上发表SCI/EI论文44篇;出版学术专著2部(华科/Springer出版社英文专著1部,科学出版社中文专著1部);授权/受理发明专利78件,包括以第一发明人授权美国发明专利1件。获上银优秀机械博士论文优秀奖、浙江省优秀博士学位论文提名奖、CJME创刊35周年优秀论文奖、机械工程学报优秀论文奖等荣誉。
● 并/混联机器人力学建模与性能设计
● 机器人装备研发与应用
● 爬壁机器人机构构型与性能优化设计
● 人形机器人结构设计
获奖情况
1. 第12届上银优秀机械博士论文优秀奖,中国机械工程学会青年论文奖,排名1,2023.
2. 面向铝合金结构件的五轴加工机器人机构设计研究,中国学位与研究生教育学会,第二届中国研究生机器人创新设计大赛特等奖,排名1,2020.
3. New Family of RPR-Equivalent Parallel Mechanisms: Design and Application,中国机械工程学会,Chinese Journal of Mechanical Engineering创刊35周年优秀论文,排名2,2023.
科研项目
1. 国家自然科学基金面上项目,50万,2026.1~2029.12,排名1
2. 第九届中国科协“青年人才托举工程”项目,30万,2024.01~2026.12,排名1
3. 国家自然科学基金青年项目,30万,2023.1~2025.12,排名1
4. 浙江省自然科学基金重点项目,30万,2026.1~2028.12,排名1
5. 中国博士后科学基金面上项目,8万,2022.1~2023.6,排名1
6. 国家自然科学基金重点项目,300万,2020.1~2024.12,排名9
7. 国家自然科学基金面上项目,65万,2018.1~2021.12,排名6
出版专著及论文
1. Li Qinchuan, Yang Chao,Xu Lingmin, Ye Wei. Performance analysis and optimization of parallel manipulators[M]. Springer, 2023.
2. 李秦川,徐灵敏,柴馨雪.机器人建模与分析的几何代数方法[M].科学出版社, 2025.
3. Xu Lingmin*, Zhou Jianxin, Jiang Hongjun, Tang Chenxin, Chen Qinye, Tang Tengfei, Liu Xiangzhi, and Li Qinchuan. Mechanism design and experimental validation of wearable torso rehabilitation robots based on parallel structures[J]. Mechanism and Machine Theory, 2026, 228: 106548.
4. Xu Lingmin*, Ye Wei, and Li Qinchuan. Evaluation method and performance indices for the motion/force constrainability of overconstrained parallel manipulators without actuation redundancy[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2025, 17(6): 061007.
5. Xu Lingmin, Chai Xinxue*, Ding Ye.Design and analysis of a reconfigurable hybrid robot for machining of large workpieces[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2024, 16(5): 051001.
6. Xu Lingmin, Chai Xinxue, Ding Ye*.Design of a 2RRU-RRS parallel kinematic mechanism for an inner-cavity machining hybrid robot[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2024, 16(5): 054501.
7. Xu Lingmin, Ye Wei, Li Qinchuan*. Design, analysis, and experiment of a new parallel manipulator with two rotational and one translational motion[J]. Mechanism and Machine Theory, 2022, 177: 105064.
8. Xu Lingmin, Shabana Ahmed. A*. A geometrically accurate deformable-body approach for the analysis of robotic and parallel-mechanism systems[J]. Mechanics Based Design of Structures and Machines. 2020, 2: 1-21.
9. Xu Lingmin, Chai Xinxue, Li Qinchuan, Zhang Liangan, Ye Wei*.Design and experimental investigation of a new 2R1T overconstrained parallel kinematic machine with actuation redundancy[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2019, 11(3): 031016.
10. Xu Lingmin, Chen Genliang, Ye Wei, Li Qinchuan*.Design, analysis and optimization of Hex4, a new 2R1T overconstrained parallel manipulator with actuation redundancy[J]. Robotica, 2018, 37(2): 358-377.
11. Xu Lingmin, Li Qinchuan*, Tong Junhua, Chen Qiaohong. Tex3: An 2R1T parallel manipulator with minimum DOF of joints and fixed linear actuators[J]. International Journal of Precision Engineering and Manufacturing, 2018, 19(2): 227-238.
12. Xu Lingmin, Chen Qiaohong, He Leiying, Li Qinchuan*. Kinematic analysis and design of a novel 3T1R 2-(PRR)2RH hybrid manipulator[J]. Mechanism and Machine Theory, 2017, 112: 105-122.
13. Xu Lingmin, Li Qinchuan*, Zhang Ningbin, Chen Qiaohong. Mobility, kinematic analysis, and dimensional optimization of new three-degrees-of-freedom parallel manipulator with actuation redundancy[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2017, 9(4): 041008.
14. Chai Xinxue,Zheng Guochang,Zheng Shuyin,Wen Feng,Xiao Yu,Xu Lingmin*, Li Qinchuan. Theoretical analysis and experimental verification of a 3RR-3RRR multi-loop coupling mechanism based on geometric algebra[J]. Robotica, 2025, 43(7): 2504-2526.
15. Chai Xinxue, Xiao Yu, Li Qinchuan,Xu Lingmin*. Actuation selection for multi-loop coupling mechanisms using geometric algebra[J]. Proceedings of the Institution of Mechanical Engineers, Part C: Journal of Mechanical Engineering Science, 2024, DOI: 10.1177/09544062241227317.
16. Chai Xinxue, Ye Wei, Li Qinchuan,Xu Lingmin*. Elastostatic stiffness modeling and performance evaluation of a 2UPR-2PRU redundantly actuated parallel manipulator[J]. Machines, 2022, 10(12): 1219.
17. Xiao Yu,Xu Lingmin, Zheng Guochang, Li Qinchuan, and Xinxue Chai*. Singularity Analysis Method of Multi-Loop Coupling Mechanism Using Geometric Algebra[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2025, 17(6): 061006.
18. Lin Ziying,Xu Lingmin, Ding Ye*, Zhu Xiangyang. A 2R1T redundantly actuated parallel manipulator with an offset moving platform and fixed linear actuators[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2023, 15(4): 041016.
19. Shen Xudong,Xu Lingmin, Li Qinchuan*. Motion/force constraint indices of redundantly actuated parallel manipulators with over constraints[J]. Mechanism and Machine Theory, 2021, 165: 104427.
20. Shabana Ahmed. A.*,Xu Lingmin. Rotation-based finite elements: Reference-configuration geometry and motion description[J]. Acta Mechanica Sinica, 2021, 37(1): 105-126.
21. Rao Chenyang,Xu Lingmin, Chen Qiaohong, Ye Wei*. Dynamic modeling and performance evaluation of a 2UPR-PRU parallel kinematic machine based on screw theory[J]. Journal of Mechanical Science and Technology, 2021, 35(6): 2369-2381.
22. Chen Zhengsheng,Xu Lingmin, Zhang Weizhong, Li Qinchuan*. Closed-form dynamic modeling and performance analysis of an over-constrained 2PUR-PSR parallel manipulator with parasitic motions[J]. Nonlinear Dynamics, 2019, 96(1): 517-534.
23. Li Qinchuan,Xu Lingmin, Chen Qiaohong*, Chai Xinxue.Analytical elastostatic stiffness modeling of overconstrained parallel manipulators using geometric algebra and strain energy[J]. Journal of Mechanisms and Robotics-Transactions of the ASME, 2019, 11(3): 031007.
24. Li Qinchuan*,Xu Lingmin, Chen Qiaohong, Ye Wei.New family of RPR-equivalent parallel mechanisms: Design and application[J]. Chinese Journal of Mechanical Engineering (研究热点论文), 2017, 30(2): 217-221.
25. 张昕,史东豪,陈芝翰,徐灵敏*,李秦川.用于微创手术的混联机器人机构设计与轨迹分层优化[J].机械工程学报, 2025, 62(11): 201-214.
26. 柴馨雪,陶奕良,祖洪飞,徐灵敏*,李秦川.基于误差模型与机器学习结合的2PRU-PSR并联机器人误差补偿方法[J].机械工程学报, 2025, 61(21): 192-203.
27. 徐灵敏,叶伟,李秦川*.并联机器人逆动力学建模的几何代数方法[J].机械工程学报, 2022, 58(7): 1-11.
28. 张伟中,徐灵敏,童俊华,李秦川*. 2-PUR-PSR并联机构的运动学分析及尺度综合[J].机械工程学报, 2018, 54(7): 45-53.
专利情况
1. Xu Lingmin, Li Qinchuan, Ye Wei. Two Rotational and One Translational Degrees of Freedom Parallel Manipulator with High Rotational Capability,美国发明专利,专利号: US10539211 B2[P], 2020.
2. 徐灵敏,李秦川,叶伟.一种驱动固定的两转动一移动弧形导轨并联机构,中国发明专利,专利号: ZL201811092419.9[P], 2024.
3. 徐灵敏,李秦川,叶伟.一种大转角两转动一移动并联机构,中国发明专利,专利号: ZL201610934656.X[P], 2018.
4. 徐灵敏,林子瑛,丁烨.双动平台两转一移三自由度并联机构及其铣削打磨设备,中国发明专利,专利号: ZL202210610170.6[P], 2025.
5. 徐灵敏,丁烨,赵言正.用于大型深腔类零件内壁打磨的折叠式可重构并联机器人,中国发明专利,专利号: ZL2022 11071340.4[P], 2025.
6. 徐灵敏,丁烨,李秦川.一种可实现大型结构件内腔检测的伸缩式机器人装备,中国发明专利,专利号: ZL02411518126.8[P], 2025.
7. 徐灵敏,郑舒尹,刘善怡,郑国畅,李秦川.用于大型复杂曲面表面打磨的移动式并联爬壁机器人设备,中国发明专利,专利号: ZL202411516844.1[P], 2025.
8. 徐灵敏,丁烨,李秦川.用于大型弯曲零件内腔检测的多自由度混联机器人装备,中国发明专利,专利号: ZL202411517216.5[P], 2025.
9. 徐灵敏,丁烨,赵言正.用于薄壁件磨抛的刚柔耦合混联式机器人装备,中国发明专利,专利号: ZL202310252941.3[P], 2025.
10. 李秦川,徐灵敏,叶伟.一种驱动固定的两转动一移动并联机构,中国发明专利,专利号: ZL201611032065.X[P], 2023.
11. 李秦川,徐灵敏,叶伟,陈正升.一种具有大摆角的两转动一移动冗余驱动并联机构,中国发明专利,专利号: ZL201711326185.5[P], 2023.
12. 李秦川,徐灵敏,柴馨雪,黄鹏成.一种转动副驱动的四自由度并联式分拣机器人,中国发明专利,专利号: ZL201510702579.0[P], 2017.
13. 李秦川,徐灵敏,柴馨雪,黄鹏成.一种移动副驱动的四自由度并联式搬运机器人,中国发明专利,专利号: ZL201510700380.4[P], 2017.
14. 柴馨雪,徐灵敏,李秦川.用于大型复杂构件加工的并联爬壁机器人装备,中国发明专利,专利号: ZL202310277676.4[P], 2025.
15. 柴馨雪,夏纯,徐灵敏,李秦川.基于等效运动链的并联机器人运动学标定方法,中国发明专利,专利号: ZL202111070626.6[P], 2022.
16. 柴馨雪,郑国畅,徐灵敏,李秦川.用于大型复杂零件加工的六自由度并联式爬壁机器人,中国发明专利,专利号: ZL202310694625.1[P], 2025.
17. 陶奕良,褚洪宇,柴馨雪,徐灵敏,李秦川.一种2PRU-PSR并联机器人的误差补偿方法,中国发明专利,专利号: ZL202411215829.3[P], 2024.
18. 李秦川,叶伟,张海峰,徐灵敏.一种含闭环结构的高刚度重载机器人,中国发明专利,专利号: ZL202510099036.8[P], 2025.
19. 徐灵敏,周子涵,王苑竹,马腾辉,柴馨雪,李秦川.一种基于多连杆直线驱动机构及多自由度的肩肘组合关节,中国发明专利,专利号:CN202611349479.9[P], 2026.
20. 徐灵敏,王文娜,柴馨雪,孔德煌,文凤,李秦川.一种用于化工储罐与异形管道内壁检测的随形爬壁机器人,中国发明专利,专利号:CN202611294066.5[P], 2026.
21. 徐灵敏,陈沁烨,黄锦程,周建鑫,柴馨雪.一种面向人体躯干康复的冗余驱动并联式装置,中国发明专利,专利号: CN202611004028.1[P], 2026.
22. 徐灵敏,张嘉轩,汤陈昕,柴馨雪,李坤,李秦川.一种电机固定的五自由度冗余驱动重载混联加工装置,中国发明专利,专利号: CN202610946958.2[P], 2026.
23. 徐灵敏,张莹,柴馨雪,汤陈昕,吴文镜,栗园园,李秦川.基于物理信息神经网络的并联机器人位姿误差补偿方法,中国发明专利,专利号: CN202610948150.8[P], 2026.
24. 徐灵敏,李坤,王文娜,陆鲁翔,柴馨雪,李秦川.一种三自由度串并联混合冗余驱动的仿人机器人腰关节,中国发明专利,专利号: CN202610893629.6[P], 2026.
25. 徐灵敏,冯馨恬,叶伟,曾权,柴馨雪,李秦川.一种基于环形导轨的仿人体颈部转动并联式机械关节,中国发明专利,专利号: CN202610569054.2[P], 2026.
26. 徐灵敏,马腾辉,王硕,王苑竹,柴馨雪,饶晨阳,李秦川.一种仿人体肩肘关节运动的多自由度机械臂,中国发明专利,专利号: CN202610444517.2[P], 2026.
27. 徐灵敏,张嘉轩,马腾辉,汤陈昕,柴馨雪,李秦川.一种可实现重载铣削的双动平台并联加工装备,中国发明专利,专利号: CN202610419115.7[P], 2026.
28. 徐灵敏,王文娜,柴馨雪,李坤,李秦川.一种用于大型曲面多场景打磨的负压吸附式爬壁机器人,中国发明专利,专利号: CN202610322080.5[P], 2026.
29. 徐灵敏,刘善怡,柴馨雪,李秦川.面向多曲率管廊的多节并联式爬行机器人,中国发明专利,专利号: CN202610223323.X[P], 2026.
30. 徐灵敏,汤陈昕,张嘉轩,柴馨雪,李坤,李秦川.一种少关节分支冗余驱动过约束重载铣削并联机器人装备,中国发明专利,专利号: CN202610243892.0[P], 2026.
31. 徐灵敏,张嘉轩,汤陈昕,柴馨雪,李秦川.一种面向重载铣削的高效过约束并联机构装备,中国发明专利,专利号: CN202610335750.7[P], 2026.
32. 徐灵敏,李坤,郭梦晴,张嘉轩,贺树祥,丁烨,李秦川.用于大型弯曲零件内腔检测的宏微协同混联机器人装备,中国发明专利,专利号: CN202610100977.3[P], 2026.
33. 徐灵敏,贺树祥,王苑竹,李秦川.一种具有多支撑平台的并联式躯干康复机器人,中国发明专利,专利号: CN202510185983.9[P], 2025.
34. 徐灵敏,刘善怡,文凤,李秦川.一种具有单分支双驱动结构的并联式躯干康复机器人,中国发明专利,专利号: CN202510185547.1[P], 2025.
35. 徐灵敏,张莹,刘善怡,贺树祥,柴馨雪,李秦川.一种用于躯干康复的五分支四自由度并联机器人,中国发明专利,专利号: CN202510186338.9[P], 2025.
36. 徐灵敏,褚洪宇,刘善怡,柴馨雪.一种移动副驱动的并联式三指手爪,中国发明专利,专利号: CN202510186737.5[P], 2025.
37. 徐灵敏,周建鑫,王苑竹,贺树祥,柴馨雪,李秦川.一种用于人形机器人的冗余驱动并联腰部机构,中国发明专利,专利号: CN202510481144.1[P], 2025.
38. 徐灵敏,王苑竹,谢镇涛,蒋鸿俊,李秦川.一种兼顾仿人体脚踝和脚掌运动的三自由度并联机构,中国发明专利,专利号: CN202510822046X[P], 2025.
39. 徐灵敏,刘善怡,柴馨雪,王麒欢,李秦川.一种基于冗余并联机构的混联式攀爬四足机器人,中国发明专利,专利号: CN202510839622.1[P], 2025.
40. 徐灵敏,丁烨,郑国畅,李秦川.一种负载非均匀分布的六自由度位姿调整并联机构,中国发明专利,专利号: CN202511454898.4[P], 2025.
41. 徐灵敏,王苑竹,李秦川.一种用于大型曲面结构件多孔同制的混联机器人装置,中国发明专利,专利号: CN202411074445.4[P], 2024.
42. 徐灵敏,刘善怡,李秦川.一种用于大型零件位姿调整的并联工作平台,中国发明专利,专利号: CN202411073985.0[P], 2024.
43. 徐灵敏,丁烨.大型航空薄壁件多孔钻削的混联机器人装备系统,中国发明专利,专利号: CN202210593086.8[P], 2022.
44. 徐灵敏,丁烨.用于大型内腔类变径零件打磨的可重构并联机器人,中国发明专利,专利号: CN202211070907.6[P], 2022.
45. 徐灵敏,丁烨,朱向阳.用于结构件内腔加工的混联机器人装备,中国发明专利,专利号: CN202211174437.8[P], 2022.
46. 徐灵敏,李秦川,叶伟,陈巧红,柴馨雪.一种驱动平行布置的两转动一移动三自由度并联机构,中国发明专利,专利号: CN201810597943.5[P], 2018.
联系方式
● 通讯地址:浙江省杭州市钱塘区2号大街928号浙江理工大学23-513
● Email: xulm@zstu.edu.cn


 师资队伍
