基本资料
尚祖峰 特聘副教授,硕士生导师
教育经历:
2015.09-2021.06,天津大学,工学博士(直博)
2019.09-2020.09,根特大学,联培博士(比利时)
2013.03-2015.07,南开大学,经济学学士
2011.09-2015.07,天津大学,工学学士
工作经历:
2021.07至今, 浙江理工大学
2023.06-2023.12,中科院香港创新研究院,访问学者
教学工作:
主讲电路原理、机器人入门等课程
指导本科生获批国创(国家级)、新苗等科研项目
指导研究生获“中国研究生机器人创新设计大赛”国赛二等奖
指导研究生获批厅局级项目、获评校级优秀毕业论文
主要研究方向
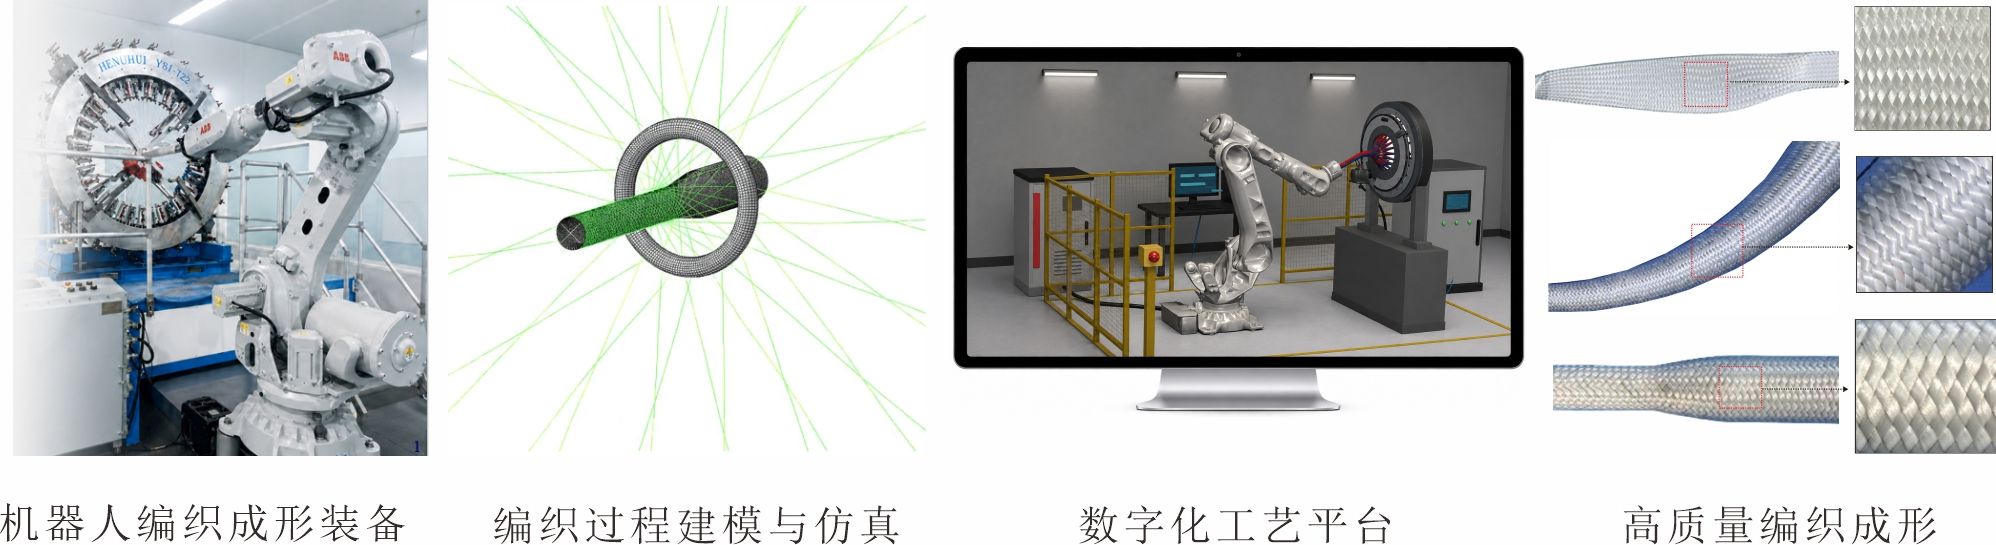
◆ 复杂复合材料构件机器人编织与智能制造
面向低空飞行器机臂、异形管梁等复杂构件的轻量化与高质量成形,研究复杂构件的机器人编织理论与制造技术,重点涉及高保真过程建模、关键成形机构与装备、机器人化成形与状态在线感知调控,以及工艺—结构—性能关联建模,推动编织制造向高精度、高适应性和智能化发展。
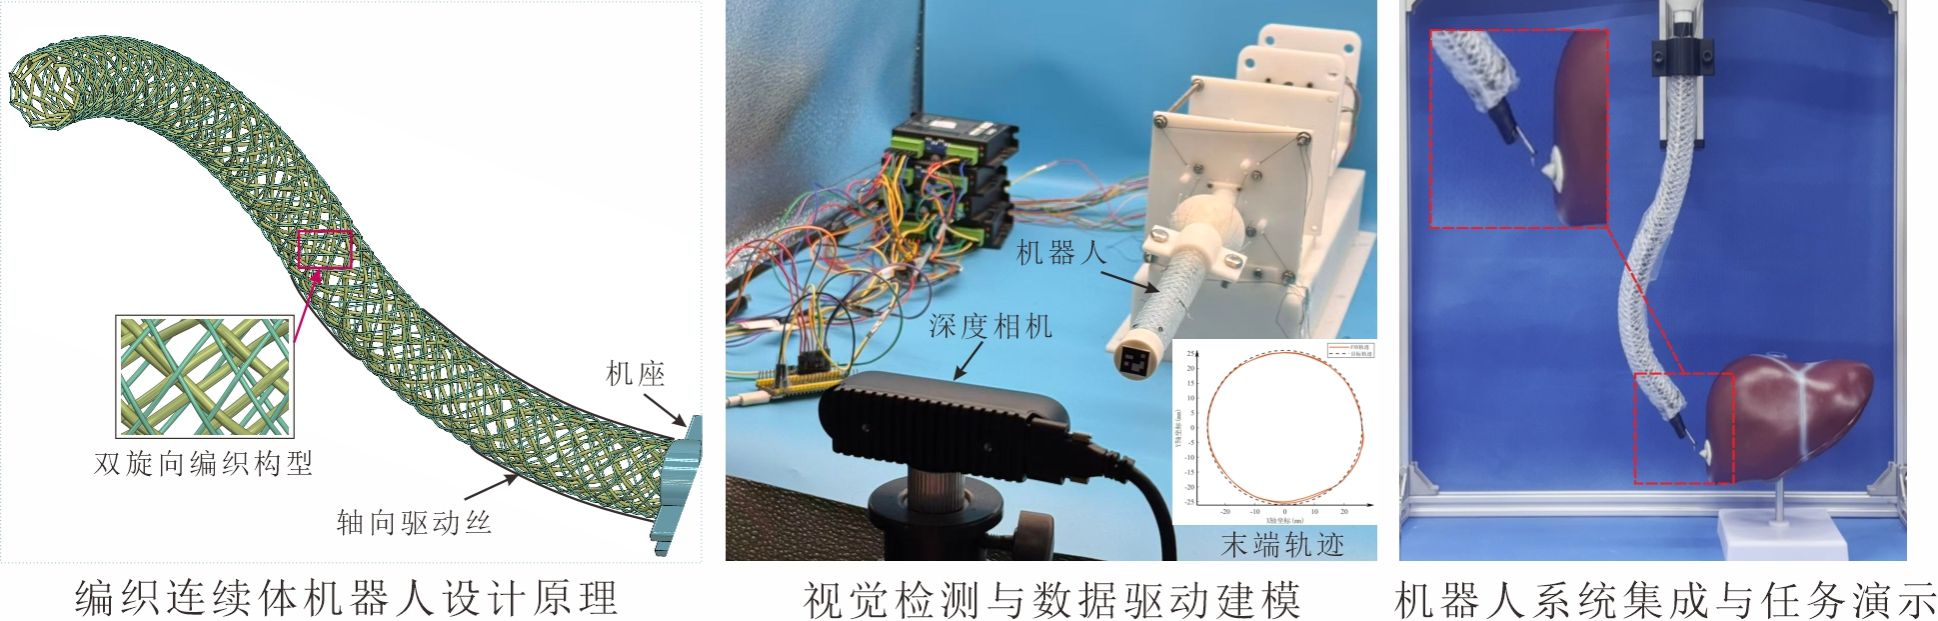
◆ 编织连续体机器人的设计、感知与操控
面向狭窄曲折空间作业需求,研究以编织结构为本体的连续体机器人设计与操控技术,重点涉及面向任务的功能构型与一体化设计、机理-数据融合运动建模、基于视觉与光纤的状态感知与形状重构,以及反馈控制、遥操作与系统集成,拓展连续体机器人多功能一体化设计与高适应性操控的实现路径。
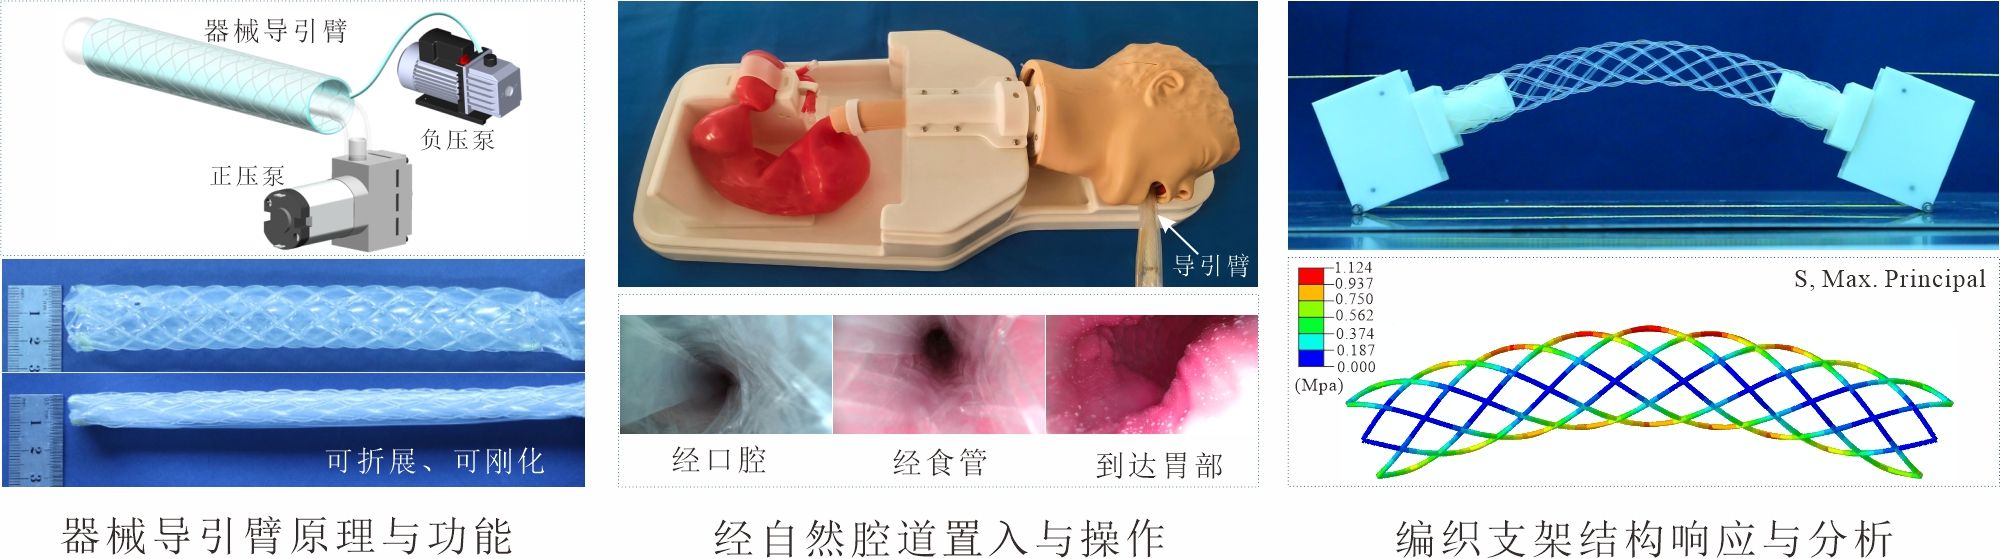
◆ 可折展微创手术器械与编织医疗结构
面向经自然腔道内镜手术和血管介入中的安全置入与稳定支撑需求,研究可折展微创手术器械与编织医疗结构,重点涉及NOTES器械导引臂的形态转换、力学调控与置入及回收,以及编织血管支架的结构响应与性能设计,探索兼顾输送适应性与原位支撑性能的微创器械设计方法。
获奖情况
1. 天津大学优秀毕业生(本科生、博士生) 2015.7/2021.06
2. 天津大学优异生(提前保研资格) 2013.12
科研项目
1. 国家自然科学基金(青年),面向自然腔道手术器械的可折展导管结构设计与刚度调控机理研究,主持
2. 浙江省自然科学基金(青年),经自然腔道手术器械入路载体的仿蚯蚓蠕动置入机理研究,主持
3. 浙江省教育厅一般项目,织物基软体抓手刚柔转换与折展驱动机理研究,主持
4. 浙江理工大学校级项目,变刚度连续机器人的功能耦合设计研究,主持
5. 国家自然科学基金(联合),大型变曲率结构件编织机器人装备设计理论与方法,参与
6. 国家自然科学基金(重大),精准微创手术器械创成与制造基础,参与
1. Self-supporting braided textile structures for soft robotics: mechanics, design, and emerging application.Textile Research Journal, 2026.
2. Design and control of a monolithically integrated robotic arm and gripper using spatially varying hybrid braided structures.IEEE Robotics and Automation Letter, 2026.(TOP)
3. FEM-informed hybrid analytical framework for equal-coverage braiding on variable-diameter mandrels.Journal of Manufacturing Processes, 2026.(一区TOP)
4. A comprehensive review on manufacturing large composites with complex irregular geometry by circular braiding.International Journal of Extreme Manufacturing, 2026.(一区TOP, IF: 25.1)
5. Modeling and constant-curvature design of a 120ospirally notched neurosurgical device using finite element method.Computer Methods in Biomechanics and Biomedical Engineering, 2025.
6. A variable-stiffness continuum manipulator using fibrous structure: design, modelling and validation.IEEE Transactions on Mechatronics, 2026.(一区TOP)
7. Design and characterization of a deployable surgical overtube based on braided structure.Part C: Journal of Mechanical Engineering Science, 2026.
8. A braided overtube with variable diameter and stiffness towards natural orifice transluminal endoscopic surgery.Smart Materials and Structures, 2025.
9. Effect of fiber orientation on the kinematical behaviors of a braided continuum manipulator.Mechanical Sciences, 2025.
10. Research on effects of braiding process on the composite preform quality using finite element method.Journal of Reinforced Plastics and Composites, 2025.
11. Flexible furniture structure based on braiding technology and fiber jamming.Mechanics of Advanced Materials and Structures, 2024.
12. Bending stiffness characterization of braided stent using spring-based theoretical formula.Archive of Applied Mechanics, 2023.
13. 面向微创手术器械臂的可变刚度机理综述.机械工程学报, 2022.
14. Lateral indentation of a reinforced braided tube with tunable stiffness.Thin-walled Structures, 2020.(一区TOP)
15. A foldable manipulator with tunable stiffness based on braided structure.Journal of Biomedical Materials Research Part B-Applied Biomaterials, 2020.
16. Self-forcing mechanism of the braided tube as a robotic gripper.Journal of Mechanisms and Robotics, 2019.
17. A hybrid tubular braid with improved longitudinal stiffness for medical catheter.Journal of Mechanics in Medicine and Biology, 2019.
18. A braided skeleton surgical manipulator with tunable diameter.8th IEEE RAS/EMBS International Conference for Biomedical Robotics and Biomechatronics, New York, 2020.
其他作者论文:
19. Height-aware navigation framework for single-DOF deformable mobile robots based on 3D encoding.IEEE Robotics and Automation Letter, 2026.
20. Yarn level finite element method simulation for bending over sheaves of braided ropes.Journal of Industrial Textiles, 2023.
21. A variable stiffness spring-sponge composite tube with fast response and shape recovery.Macromolecular Materials and Engineering, 2018.
22. A specimen extraction instrument based on braided fiber tube for natural orifice translumenal endoscopic surgery.Journal of Medical Devices, 2018.
23. 具有折展与变刚度特征的NOTES手术器械臂.机械工程学报,2018.
1. 一种基于完整自由段接触搜索的机器人编织异形芯模沉积轨迹与收敛距离测量方法,发明专利,已申请.
2. 机器人编织仿真软件,软件著作,已登记.
3. 一种动态收敛的机器人编织轨迹生成方法及系统,发明专利,已申请.
4. 一种齿轮传动的可变直径编织机导线环,实用新型,已申请.
5. 一种具有双锭子盘的径向环形编织机,发明专利,已授权.
6. 一种具有双锭子盘的轴向环形编织机,发明专利,已授权.
柔性机器人:
1. 一种蠕动置入导引机器人系统及其控制方法,发明专利,已申请.
2. 一种基于分布式光纤光栅进行形状感知的编织式柔性操作臂及其反馈控制方法,发明专利,已授权.
3. 一种基于编织管结构的一体式柔性抓手,发明专利,已申请.
4. 一种可变刚度的薄片状柔性编织抓手,发明专利,已授权.
5. 一种通过抛/收绳索实现移动的机器人及机器人移动方法,发明专利,已申请.
6. 一种直径可变的编织式管状柔性臂驱动装置,发明专利,已申请.
7. 一种编织式自然腔道手术器械臂及其径向逐序展开方法,发明专利,已申请.
8. 一种流体压力驱动的可折叠软体操作臂,申请号:发明专利,已申请.
9. 一种通过电磁驱动的编织式柔性驱动器系统,发明专利,已授权.
10. 一种管状薄壁连续体结构及柔性机械臂,发明专利,已授权.
11. Sponge-based variable-stiffness natural orifice surgery instrument support structure and use method, US Patent, Patent Number: 12016537B2.
12. 一种自然腔道手术用可展变刚度蛇形载体,发明专利,已授权.
13. 一种用于自然腔道手术的折展变刚度器械臂,发明专利,已授权.
14. 一种用于自然腔道手术的变刚度保护鞘及其应用方法,发明专利,已授权.
15. 基于海绵的变刚度自然腔道手术器械支撑结构及使用方法,发明专利,已授权.
16. 变刚度自然腔道手术器械支撑结构及使用方法,发明专利,已授权.
联系方式
● 通讯地址:浙江省杭州市钱塘区浙江理工大学15楼225室
● Email: zufeng_shang@zstu.edu.cn


 师资队伍
